Description
Size-specific context
Where JDLB 55 sits in the range
JDLB 55 is the first size in the range with the documented input-shaft diameter increasing to 18 mm and a broader ratio list that includes an 80:1 supplemental context. The dual-lead principle lets the assembled mesh be adjusted by moving the worm axially; it does not make the bare shaft interchangeable with another family size.
For a size-55 replacement, check whether the existing reducer uses one of the supplemental ratios. Those configurations should be identified explicitly because the ratio changes worm start/lead data.
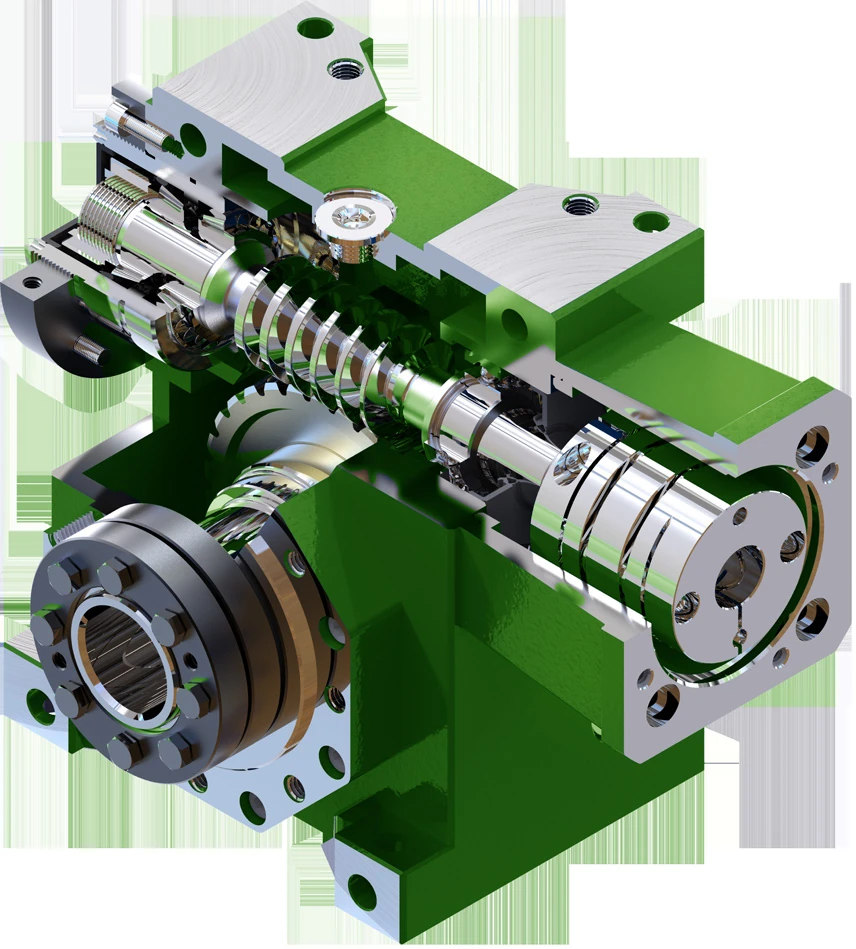
JDLB 55 size and adjustment data
| Parameter | Specification / guidance |
|---|---|
| Series size | JDLB 55 |
| Drive concept | Dual-lead worm drive with axial backlash adjustment |
| Documented ratio contexts | 14.5, 19.5, 24.5*, 30, 40*, 45, 50*, 60, 80*, 90 |
| Lead-angle examples | 12°20′ at 14.5; 10°02′ at 19.5; 6°14′ at 30; 4°36′ at 45; 3°37′ at 60; 2°33′ at 90 |
| Adjustment distance V | 8 mm |
| Adjustment coefficient k | 0.015–0.05 mm⁻¹ |
| Clearance adjustment ΔSd | 0.12–0.40 mm |
| Input shaft diameter J | 18 mm |
| Envelope A / B / C | 120 / 155 / 61 mm |
| Drive-level P0 grade | 2 arc minutes |
| Drive-level P1 grade | 3–5 arc minutes |
| Documented output radial load Fr2 | 6700 N |
| Documented output axial load Fa2 | 4600 N |
| Material / heat treatment of replacement shaft | Confirm from ordered drawing or approved project specification |
Selected JDLB 55 performance references
| Ratio context | Documented performance reference |
|---|---|
| Ratio 14.5 | At n1=1400 min⁻¹: dynamic efficiency 0.81; rated input power 1.2 kW; output torque 101 Nm; output speed 96.6 min⁻¹. |
| Ratio 45 | At n1=1400 min⁻¹: dynamic efficiency 0.64; rated input power 0.6 kW; output torque 110 Nm; output speed 31.1 min⁻¹. |
| Ratio 90 | At n1=1400 min⁻¹: dynamic efficiency 0.50; rated input power 0.4 kW; output torque 100 Nm; output speed 15.6 min⁻¹. |
Adjustment data for JDLB 55
The documented adjustment range for size 55 uses V=8 mm, k=0.015–0.05 mm⁻¹ and ΔSd=0.12–0.40 mm. These values describe the reducer adjustment context and should not be converted into a standalone tooth tolerance on a replacement shaft.
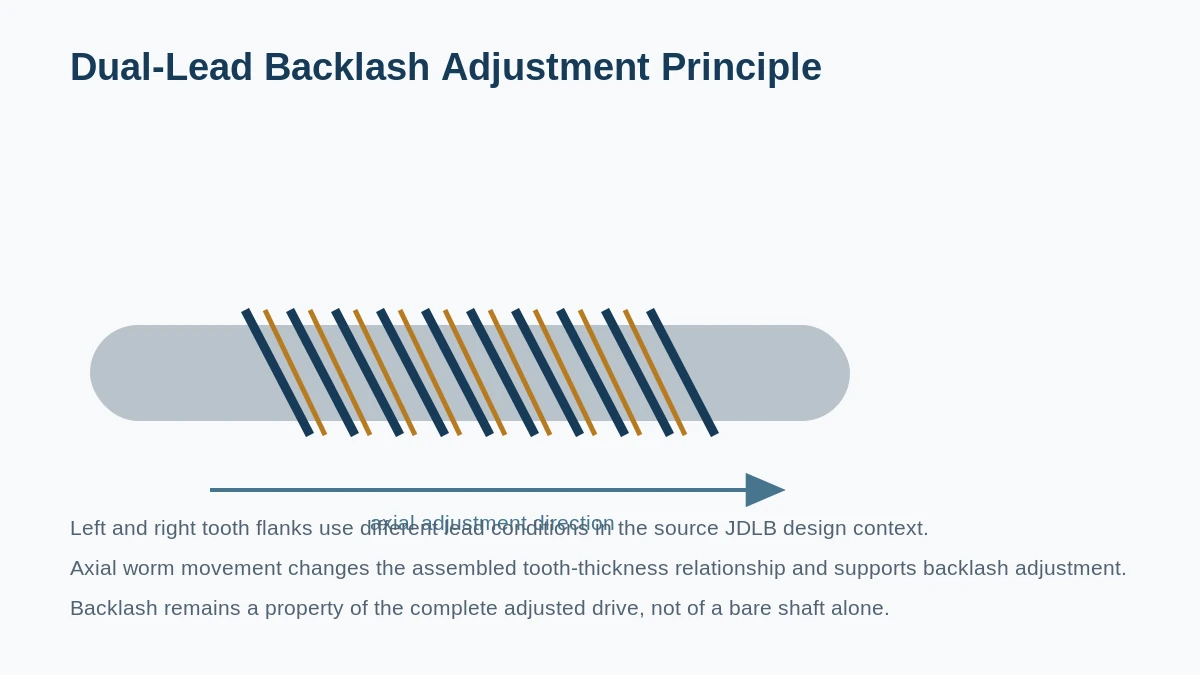
Ratio, starts and replacement identification
The size-55 mesh table spans these documented ratio contexts: 14.5, 19.5, 24.5*, 30, 40*, 45, 50*, 60, 80*, 90. Worm start count and lead angle change with the selected ratio, so the reducer size alone is not enough to manufacture a replacement worm.
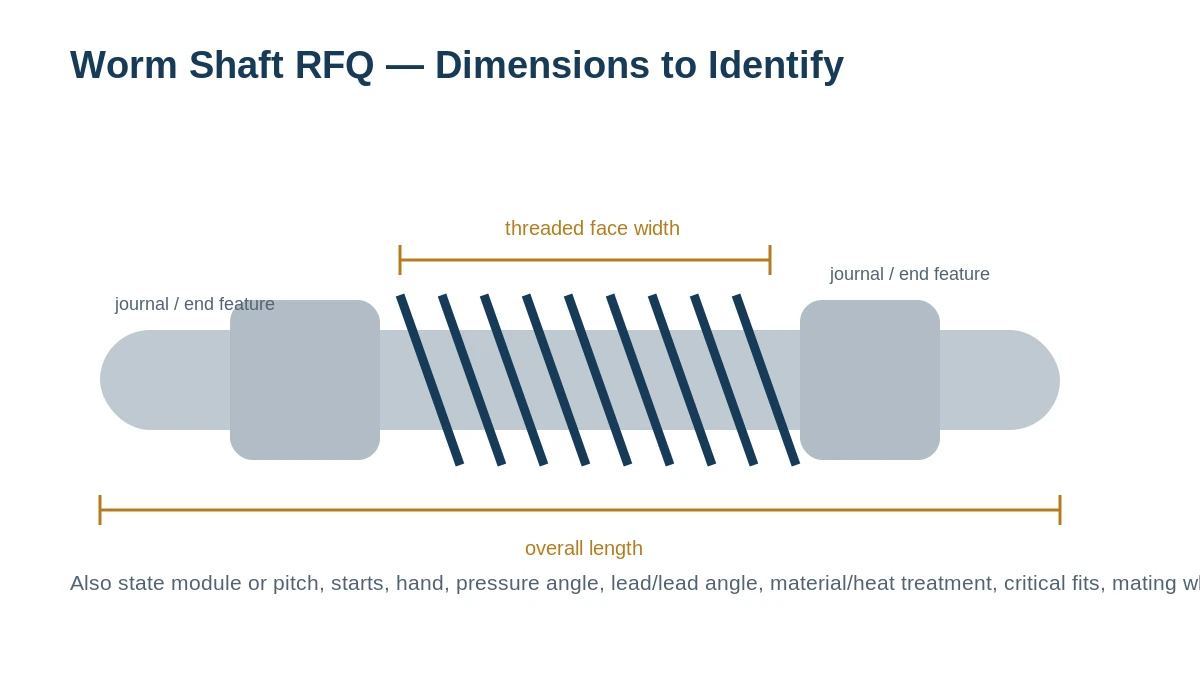
When the old shaft is worn, read the ratio plate or gearbox record and inspect the mating wheel before finalizing tooth geometry. For JDLB 55, also include the shaft end interfaces and bearing-journal dimensions in the same RFQ.
Replacement RFQ
What to send for a JDLB 55 quote
Send the size-55 reducer reference, ratio, quantity, current worm-shaft drawing or measured sample, and the mating-wheel condition. Mark any surfaces affected by wear so measured damage is not treated as intended geometry.
For JDLB 55, the order review should reflect that the first size in the range with the documented input-shaft diameter increasing to 18 mm and a broader ratio list that includes an 80:1 supplemental context. State the requested 2 arc minutes P0 or 3–5 arc minutes P1 drive grade as an assembled-mesh target and include the wheel condition plus the documented V=8 mm adjustment context.
Frequently asked questions
Does JDLB 55 include an 80 ratio context?
Yes, the documented series table includes 80 as a supplemental ratio context for size 55; final component geometry still follows the exact ordered configuration.
Can JDLB 55 be ordered from the size number alone?
No. The 55 family still contains different ratio/start/lead conditions. Send the ratio and current shaft or wheel data so the tooth relationship can be confirmed.
What if the JDLB 55 wheel is also worn?
Quote the size-55 worm and wheel together when wear or contact condition makes the original mesh uncertain. Pair-level review avoids treating a damaged mating member as a valid reference.
Replacement / service
Use JDLB 55 as a drive-family reference, then confirm the actual shaft
The JDLB 55 page carries documented series context for a dual-lead worm drive, including size-specific envelope, adjustment and selected drive-performance references already shown above. Those figures describe the drive family; they do not define every bearing journal, end feature or replacement shaft dimension.
A JDLB 55 request should separate the documented family data from the machine-specific shaft ends and bearing seats. Record the existing ratio, adjustment state and wheel condition, especially when increased lost motion is the maintenance trigger.
JDLB 55 order-release checklist
| Release item | Information to supply |
|---|---|
| Drive identity | JDLB 55 size reference plus ratio / model information. |
| Existing shaft | Drawing, sample, or trusted dimensions for journals, shoulders and input/end interfaces. |
| Mating wheel | Current wheel condition and identifying data; include it when tooth geometry or contact is uncertain. |
| Adjustment state | Current axial adjustment/reference position and the reason for replacement or backlash correction. |
| Duty | Input speed, load/torque context, reversals and lubrication condition. |
| Inspection | State whether the order needs dimensional records, material/treatment evidence or pair/assembly checks. |
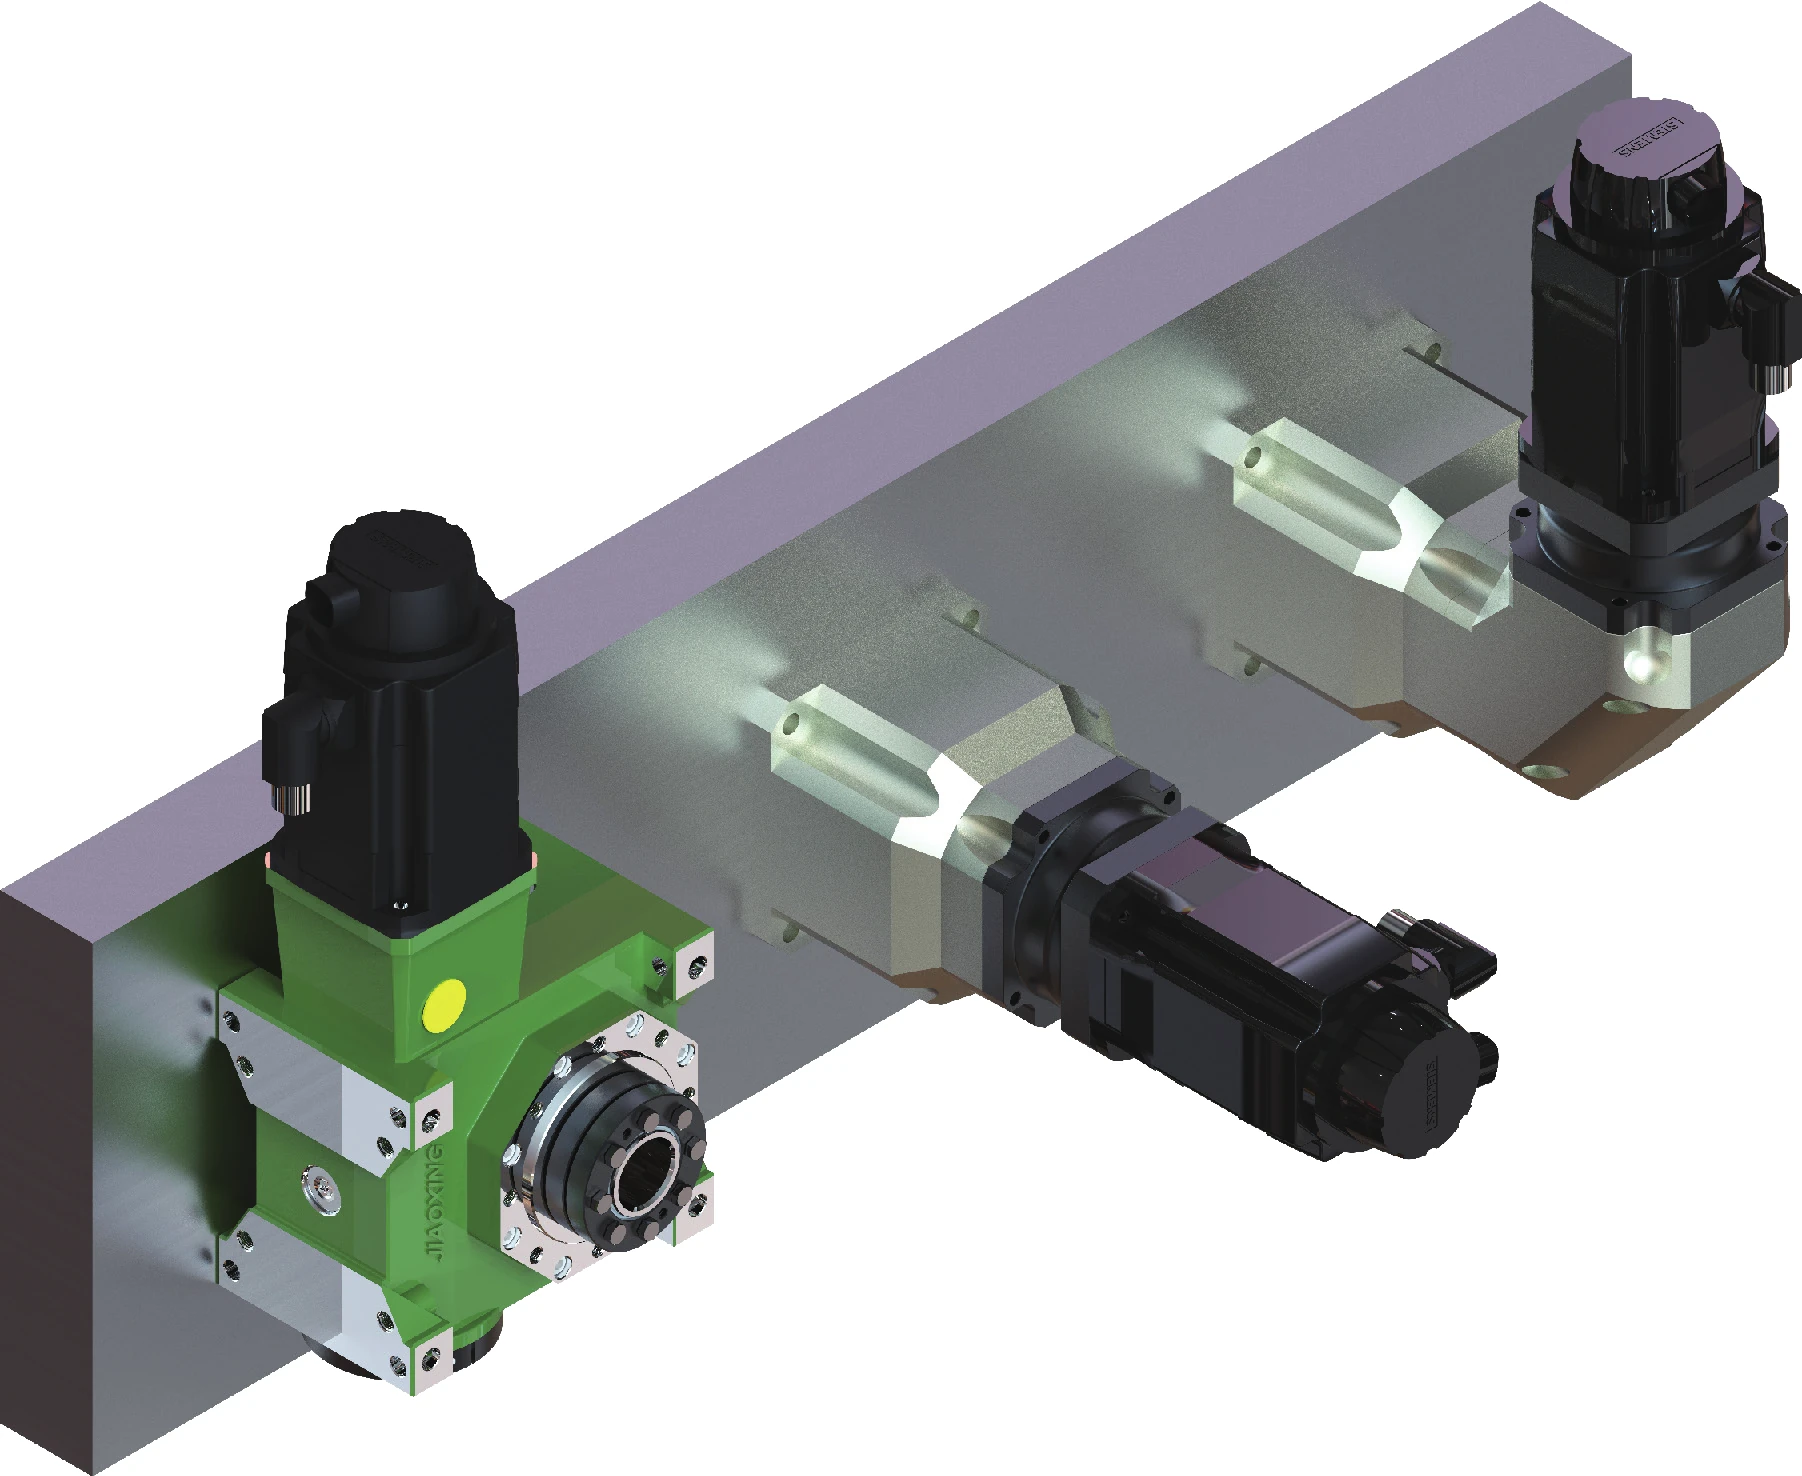
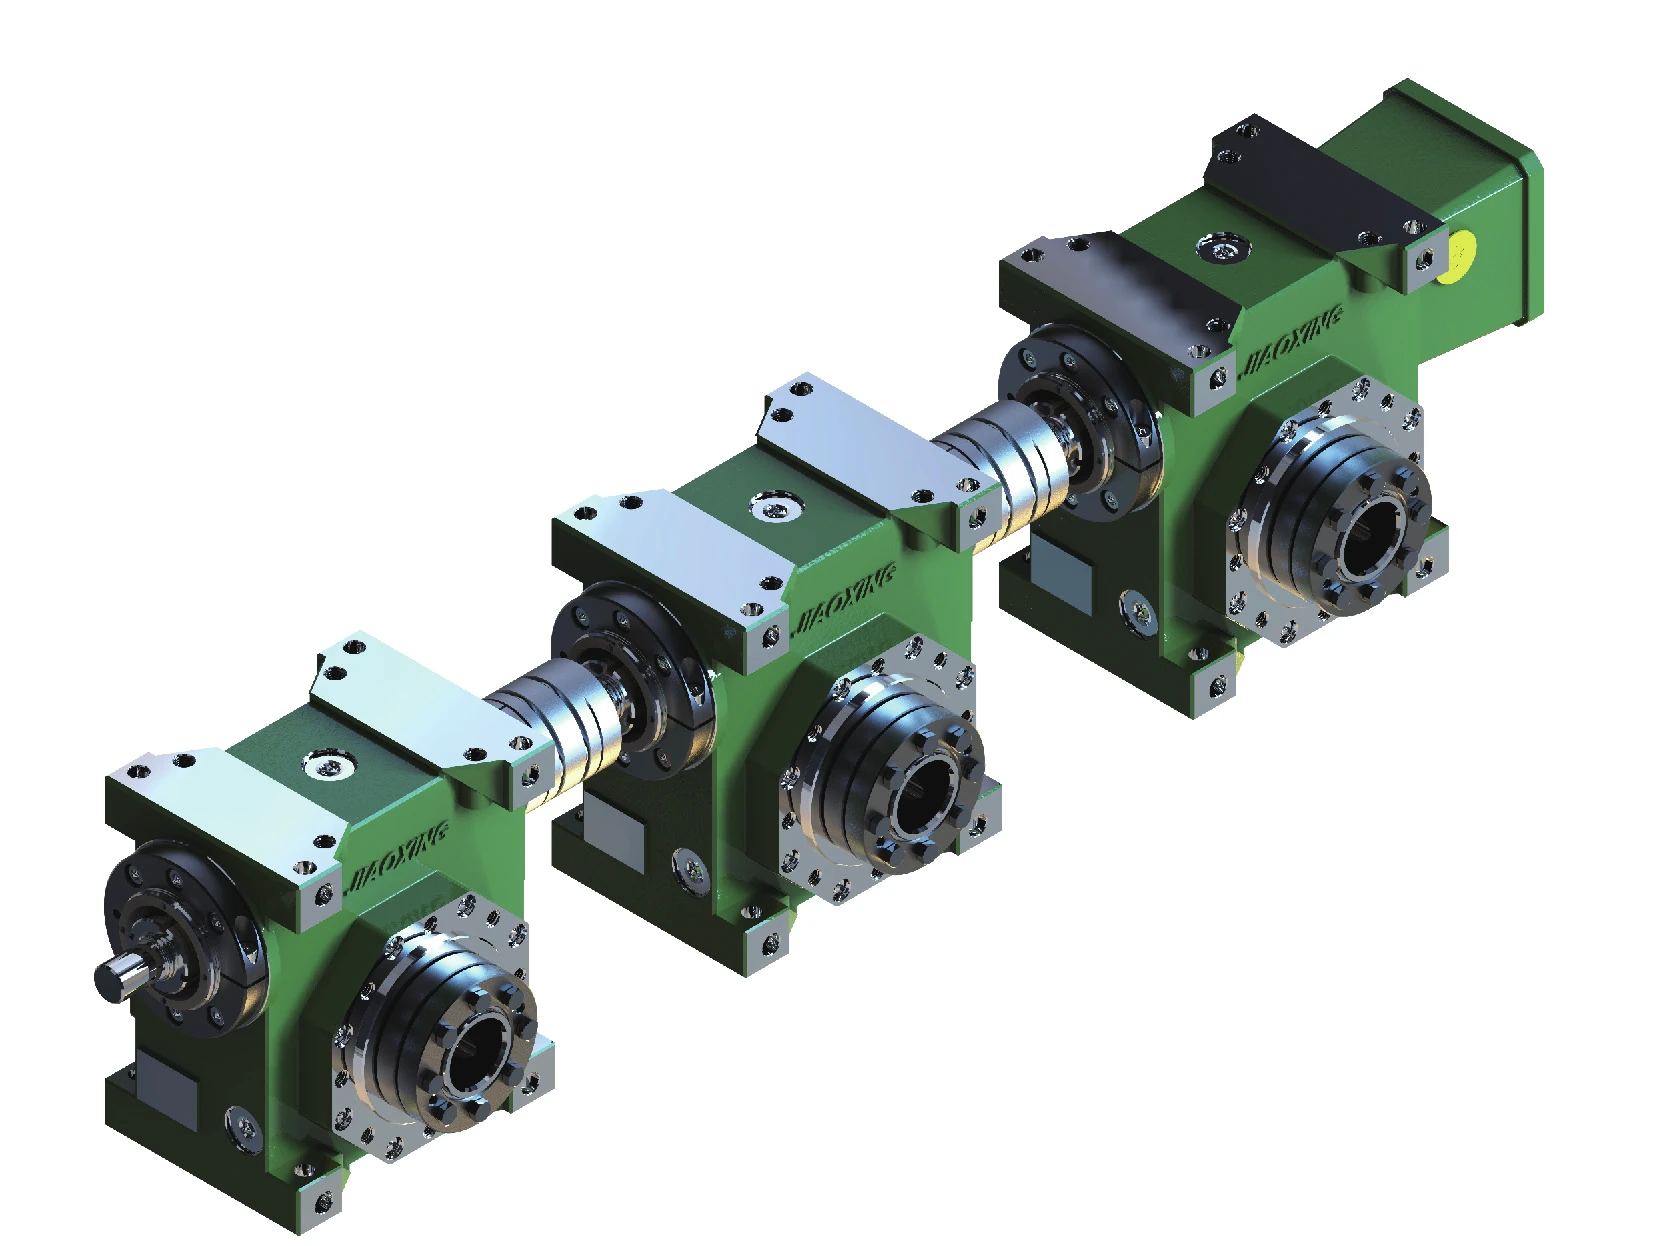
Where the JDLB 55 shaft sits in a multi-unit drive context
For linked size-55 units, provide the series arrangement and center-to-center layout used by the machine. The multi-unit diagram is useful as a configuration cue, while the actual dimensions remain controlled by your assembly or part definition.
Quote from the real interfaces
Request a Quote / Send RFQ
Send the model or drawing reference, quantity, application and the geometry that controls fit and mesh. Unknown values can be identified for confirmation rather than guessed.